Autonomous drone navigating procedurally generated terrain in C++ / OpenGL. A control loop steers the drone through the simulated environment in real time, with the surrounding world meshed on the fly using marching cubes over a 3D scalar field.
Progress
Improved marching-cubes meshing in motion. Smoother surfaces and fewer artifacts at the chunk seams compared to the initial implementation.
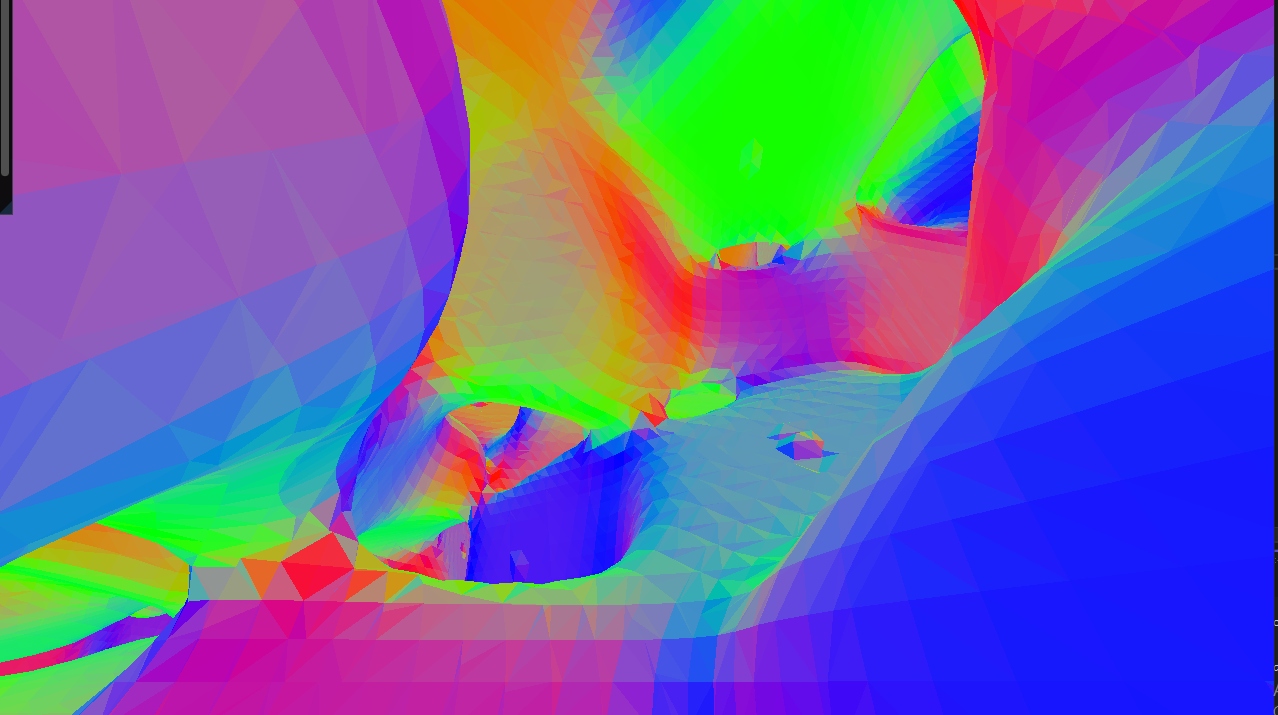
Debug pass: absolute world-space normals shaded directly onto the terrain to verify that the marching-cubes output looks correct before any lighting is applied.
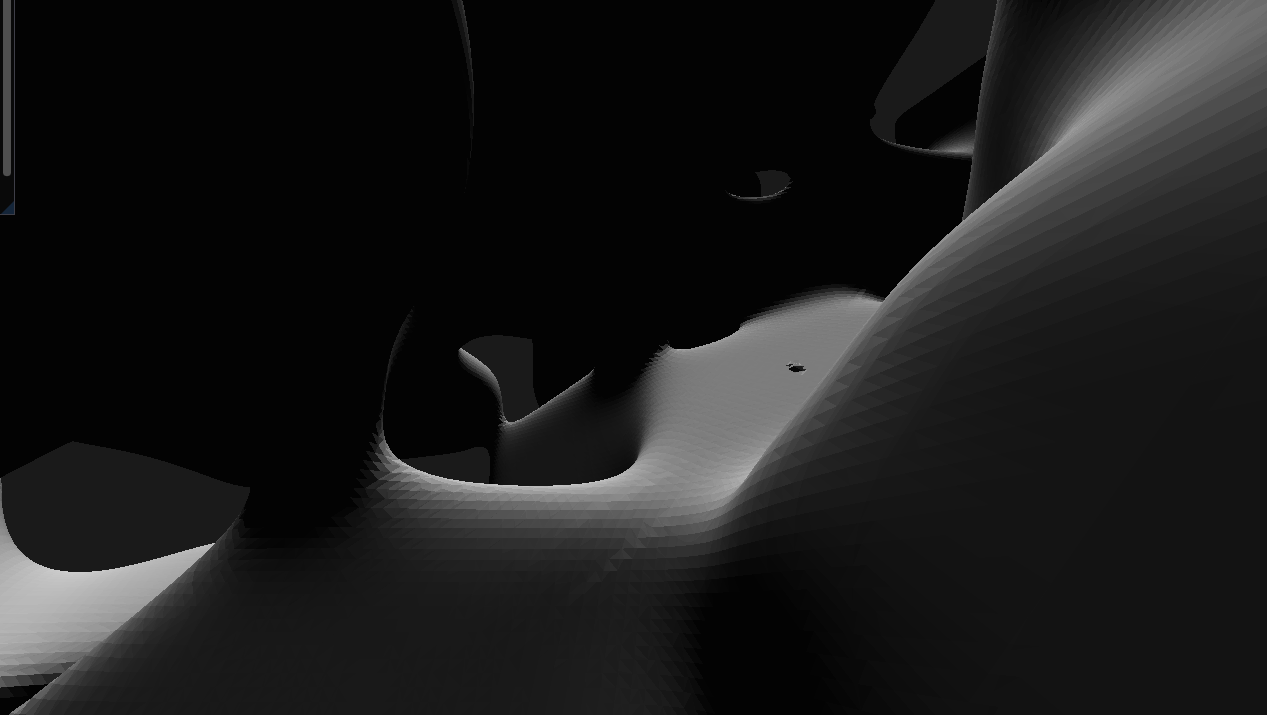
Sizing the procedural terrain chunks relative to the drone, used for collision tests and tuning the navigation control loop.
Tech stack
- Language: C++
- Graphics: OpenGL with GLSL shaders
- Terrain: Marching cubes on a 3D scalar field
- Build: CMake